Robotics · Vision
AprilTag Odometry
Verification System
A visual checkpoint for robot position, from camera detections to odometry verification.
This website is still being developed and updated.
Things I’ve built, tested, and learned from.
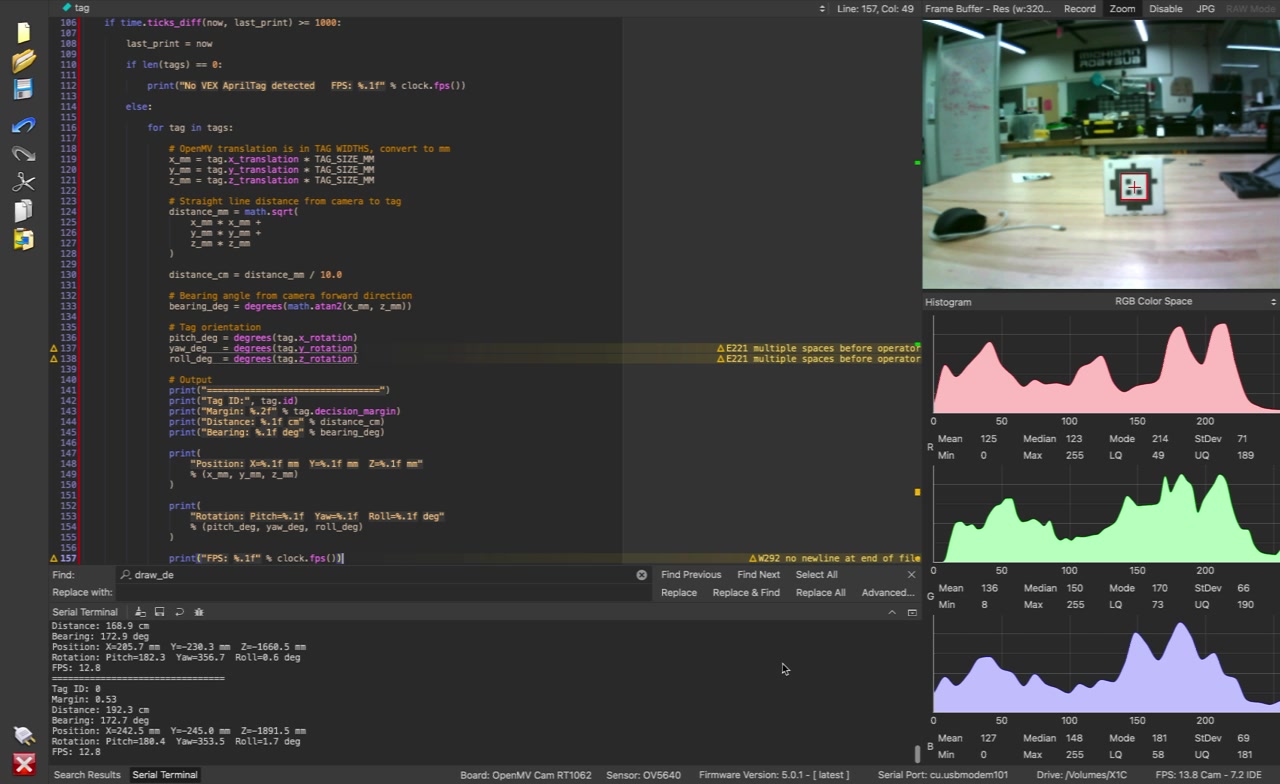
Uses AprilTag detections to verify robot odometry through a custom vision data pipeline and a PCB connecting a third-party camera to the robot’s brain.
A responsive personal website for my projects, coursework, résumé, and contact information.
Uses distance sensors, filtering, and synchronization to verify robot position against a primary tracking system.
Builds recursive templated binary-search-tree and map abstractions with traversal, iterators, copying, and memory management.
Implements a linked-list-backed text buffer with cursor movement, insertion, deletion, and row and column tracking.
Trains a probabilistic text classifier with sets, maps, label priors, word likelihoods, and log-probability scoring.
Models cards, packs, players, dealing, trump selection, trick scoring, and automated player strategies.
Resizes PPM images with seam carving by computing pixel energy, cost paths, and removable seams.
This robotics system uses distance-sensor measurements to independently verify a robot’s estimated position against its primary tracking system. The readings are filtered and synchronized before comparison, reducing the effect of noisy sensor data.
The project combines sensor integration, data filtering, and robot control to provide a secondary position check when evaluating odometry performance.